AEGIS — The Intelligent Escort
A personal safety companion built on the Unitree G1 EDU robot for the TKS Unitree SDK Challenge.
The starting point.
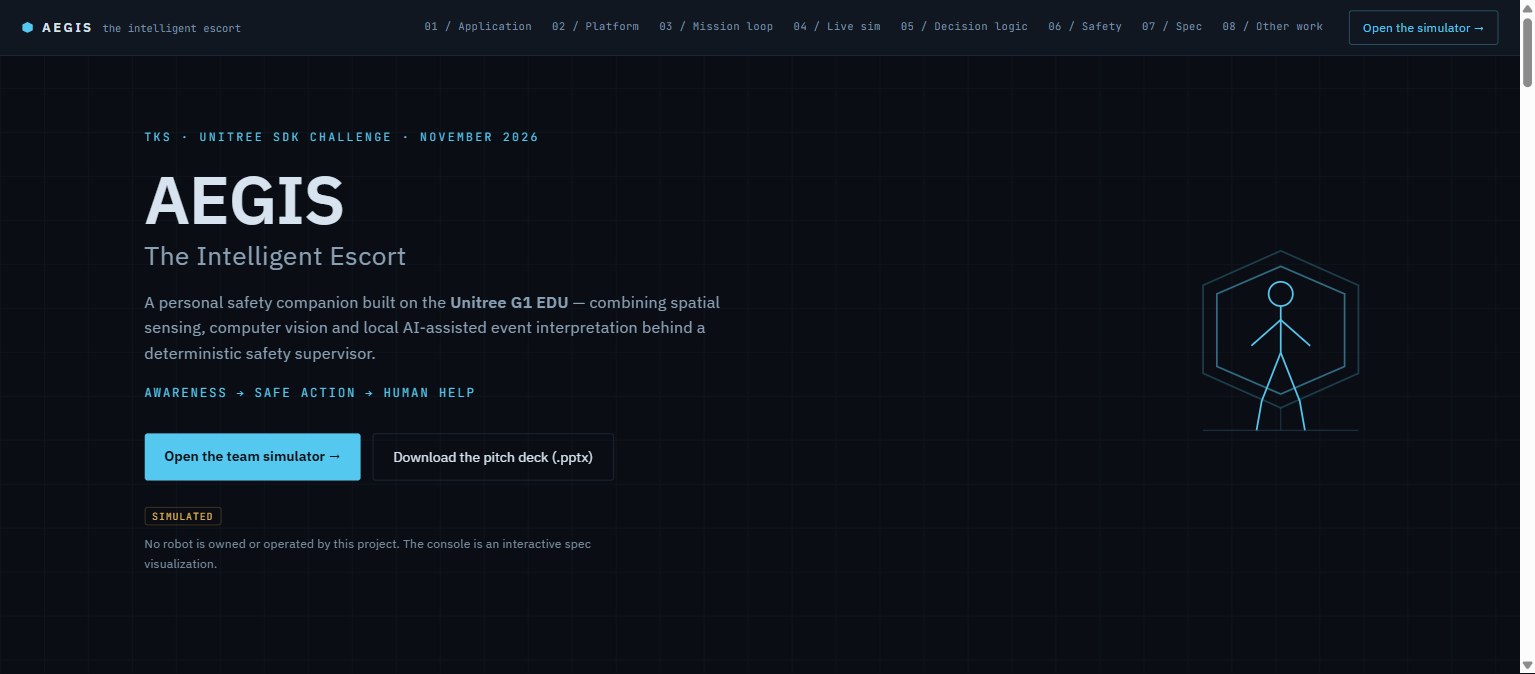
AEGIS is a personal safety companion built on the Unitree G1 EDU robot. It combines spatial sensing, computer vision and local AI-assisted event interpretation, all placed behind a deterministic safety supervisor that has final authority over physical movement. A constrained eight-step mission loop — pair, pre-flight, localize, track, plan, move, respond, end — with explicit stop conditions and human escalation. AEGIS is not a combat robot: no striking, grabbing, chasing, restraining or autonomous confrontation. It warns, pauses, creates distance, guides and alerts. The project page also documents three corrections verified against the official Python SDK — Lie2StandUp() rather than StandUp(), Move() only valid with continous_move=True, and GetFsmId() for readiness polling.
Challenge project documented, with architecture and console prototype delivered. No robot is owned or operated: everything is simulated.